Avatar

Sungwon Hwang

Ph.D · Staff Engineer

Samsung Research

Seoul, South Korea


CV | Google Scholar | LinkedIn


I am a Staff Engineer at Samsung Research in Seoul, South Korea, where I work on World Action Model to help robots perform a wide range of tasks. I received my Ph.D. in AI from KAIST Graduate School of AI in August 2026, advised by Prof. Jaegul Choo. Previously, I interned at Meta Reality Labs and NAVER LABS.

My research focuses on world models and robot learning, connecting visual understanding and prediction with action in the physical world. I am interested in how generative models and 3D representations can help robots learn transferable skills and adapt to new tasks and environments.

Contact

  • sungw.hwang [at] samsung.com

  • Seoul, South Korea

Education

  • Ph.D | KAIST Graduate School of AI

    2022.02 - 2026.08

    Advisor: Prof. Jaegul Choo

  • M.S | KAIST School of Electrical Engineering

    2020.02 - 2022.02

    Advisor: Prof. Hyun Myung

  • B.S | KAIST Dept. of Mechanical Engineering

    2014.08 - 2020.02

Professional Experiences

  • Samsung Research | AI Core Team
    Staff Engineer | Advisor: Jeongseop Kim
    Sept. 2026 - Present
    Seoul, South Korea
  • Meta Reality Labs | Codec Avatars Team
    Research Intern | Advisor: Timur Bagautdinov and Egor Zakharov
    May 2025 - Nov. 2025
    Pittsburgh, USA
  • NAVER LABS | Spatial AI Team
    Research Intern | Advisor: Suyong Yeon
    July 2024 - Oct 2024
    Seongnam, Korea

Publications

  • HumanAnything: Spatially-Aligned Multi-Modal Video Diffusion for Human-Centric Generation

    Sungwon Hwang, Egor Zakharov, Junxuan Li, Felix Taubner, Jin Kyu Kim, Itai Druker, Jaegul Choo, Timur Bagautdinov

    Proceedings of the European Conference on Computer Vision (ECCV), 2026, MUSTCV Workshop, Oral presentation

    Paper | Project Page

  • SphereDiff: Tuning-free 360° Static and Dynamic Panorama Generation via Spherical Latent Representation

    Minho Park*, Taewoong Kang*, Jooyeol Yun, Sungwon Hwang, Jaegul Choo

    Association for the Advancement of Artificial Intelligence (AAAI), 2026, Oral Presentation

    Paper | Project Page | Code

  • SurFhead: Affine Rig Blending for Geometrically Accurate 2D Gaussian Surfel-based Head Avatars

    Jaeseong Lee*, Taewoong Kang*, Marcel C. Bühler, Min-Jung Kim, Sungwon Hwang, Junha Hyung, Hyojin Jang, Jaegul Choo

    The International Conference on Learning Representations (ICLR), 2025

    Paper | Project Page | Code

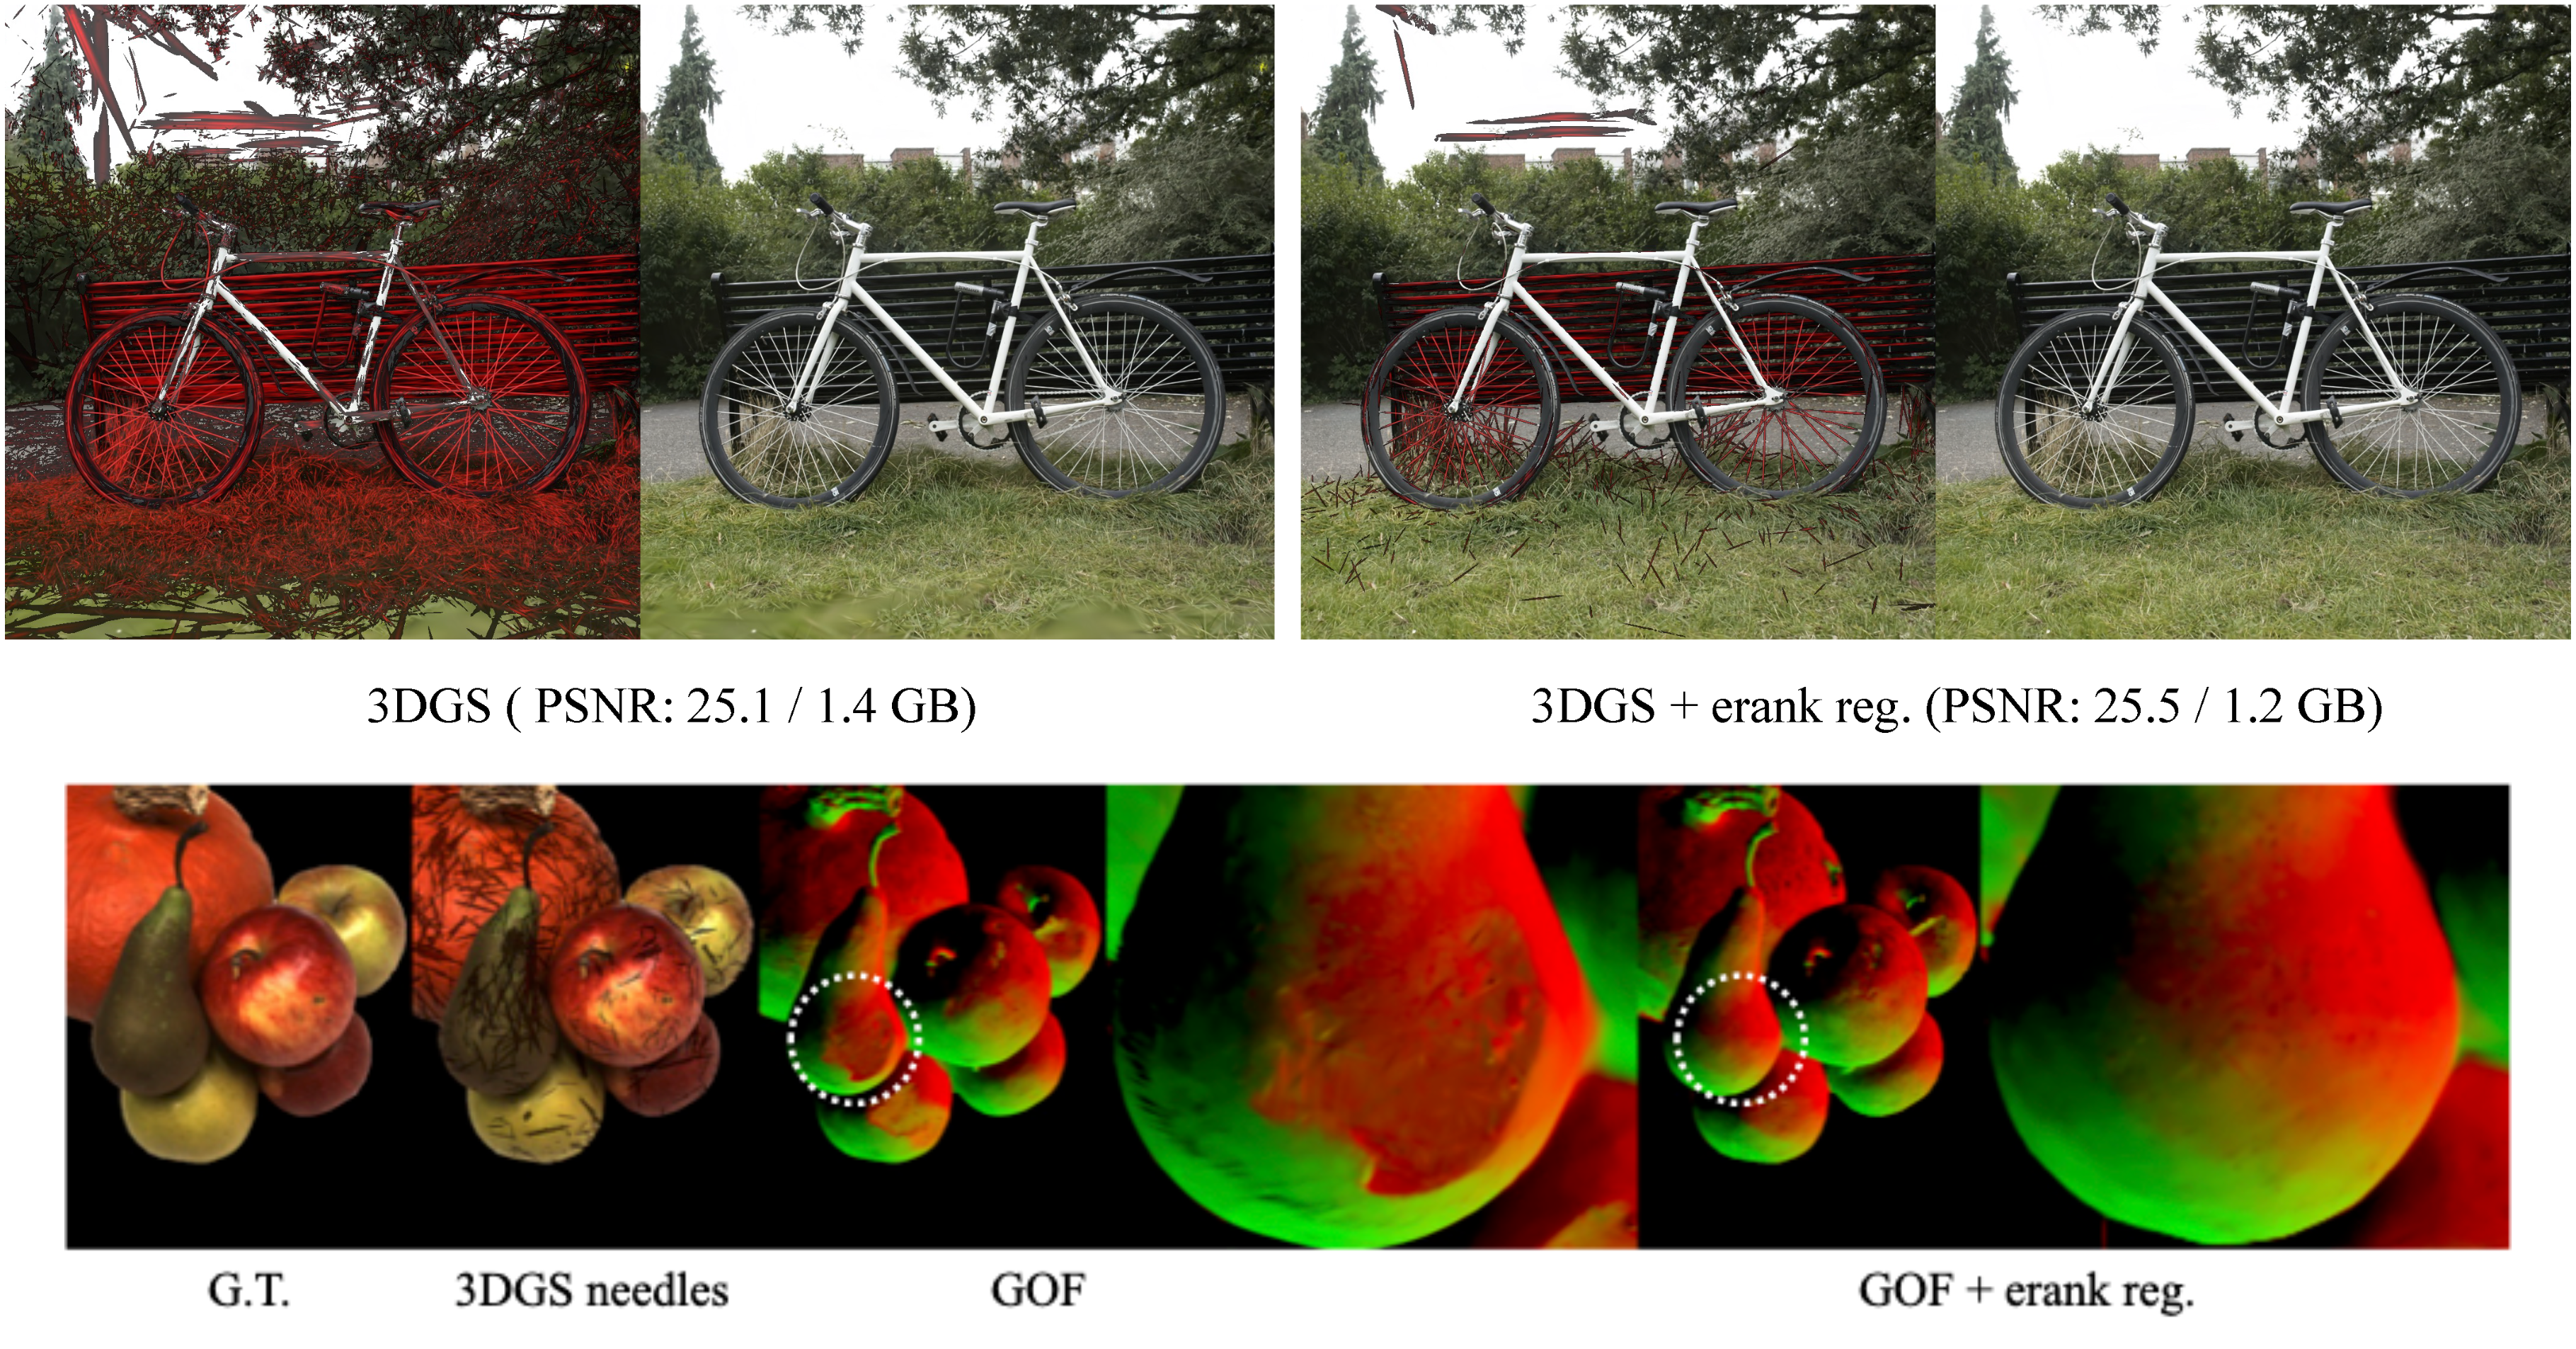
  • Effective Rank Analysis and Regularization for Enhanced 3D Gaussian Splatting

    Junha Hyung, Susung Hong, Sungwon Hwang, Jaeseong Lee, Jaegul Choo, Jin-Hwa Kim

    Advances in Neural Information Processing Systems (NeurIPS), 2024

    Paper | Project Page

  • VEGS: View Extrapolation of Urban Scenes in 3D Gaussian Splatting using Learned Priors

    Sungwon Hwang*, Min-Jung Kim*, Taewoong Kang, Jayeon Kang, Jaegul Choo

    Proceedings of the European Conference on Computer Vision (ECCV), 2024

    Paper | Project Page | Code

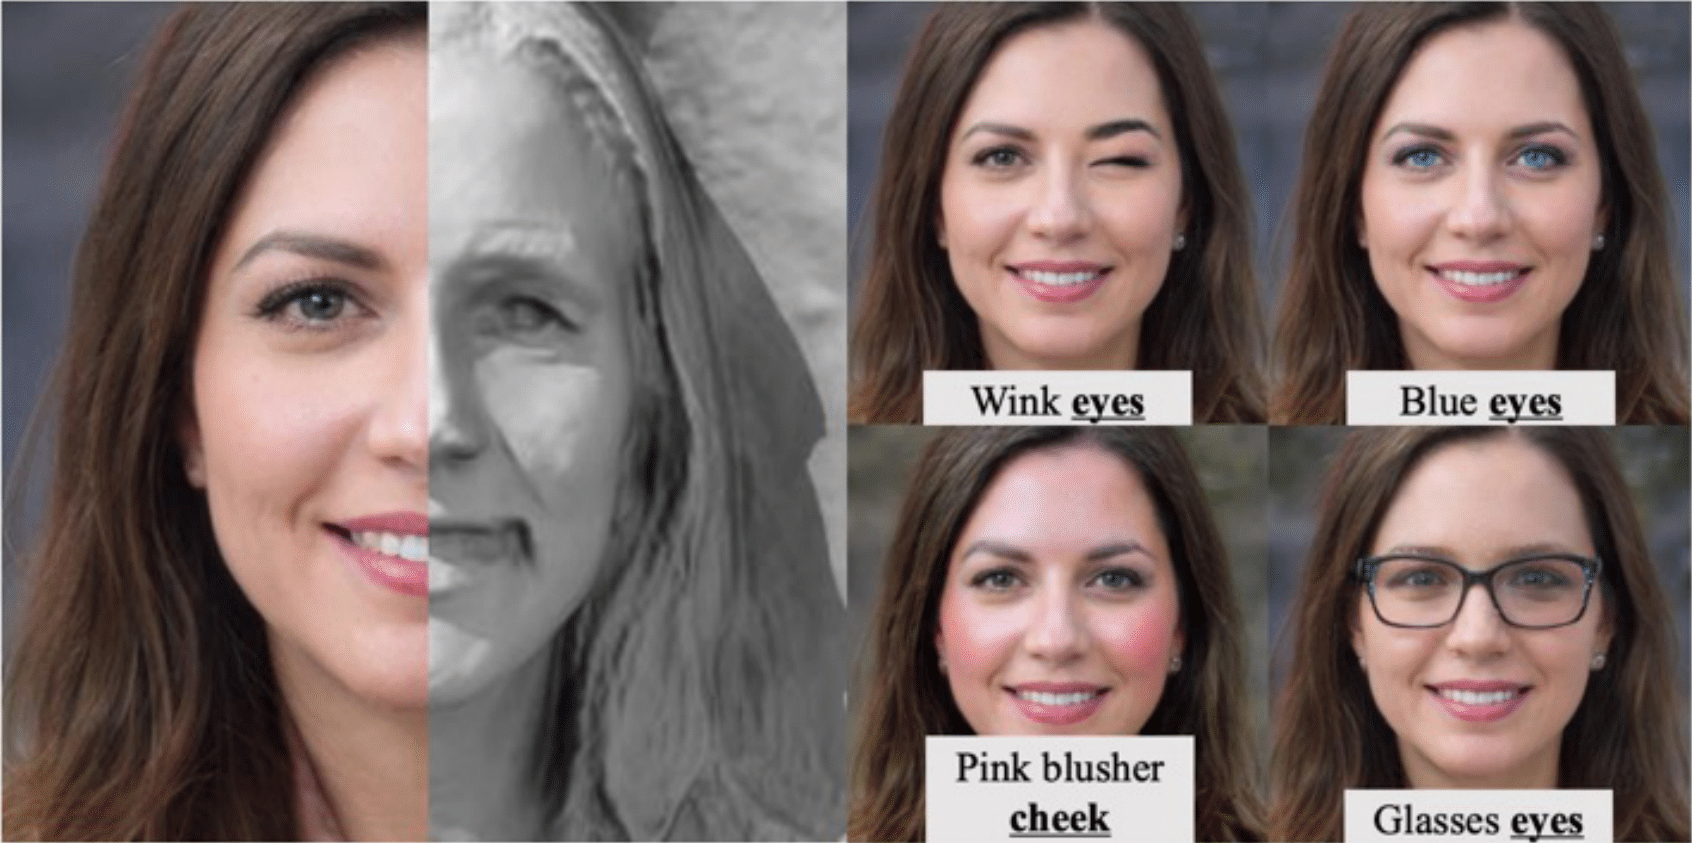
  • FaceCLIPNeRF: Text-driven 3D Face Manipulation using Deformable Neural Radiance Fields

    Sungwon Hwang, Junha Hyung, Daejin Kim, Min-Jung Kim, Jaegul Choo

    Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV), 2023

    Paper | Project Page

  • Local 3D Editing via 3D Distillation of CLIP Knowledge

    Junha Hyung, Sungwon Hwang, Daejin Kim, Hyunji Lee, Jaegul Choo

    Proceedings of the IEEE/CVF Converence on Computer Vision and Pattern Recognition(CVPR), 2023

    Paper | Code

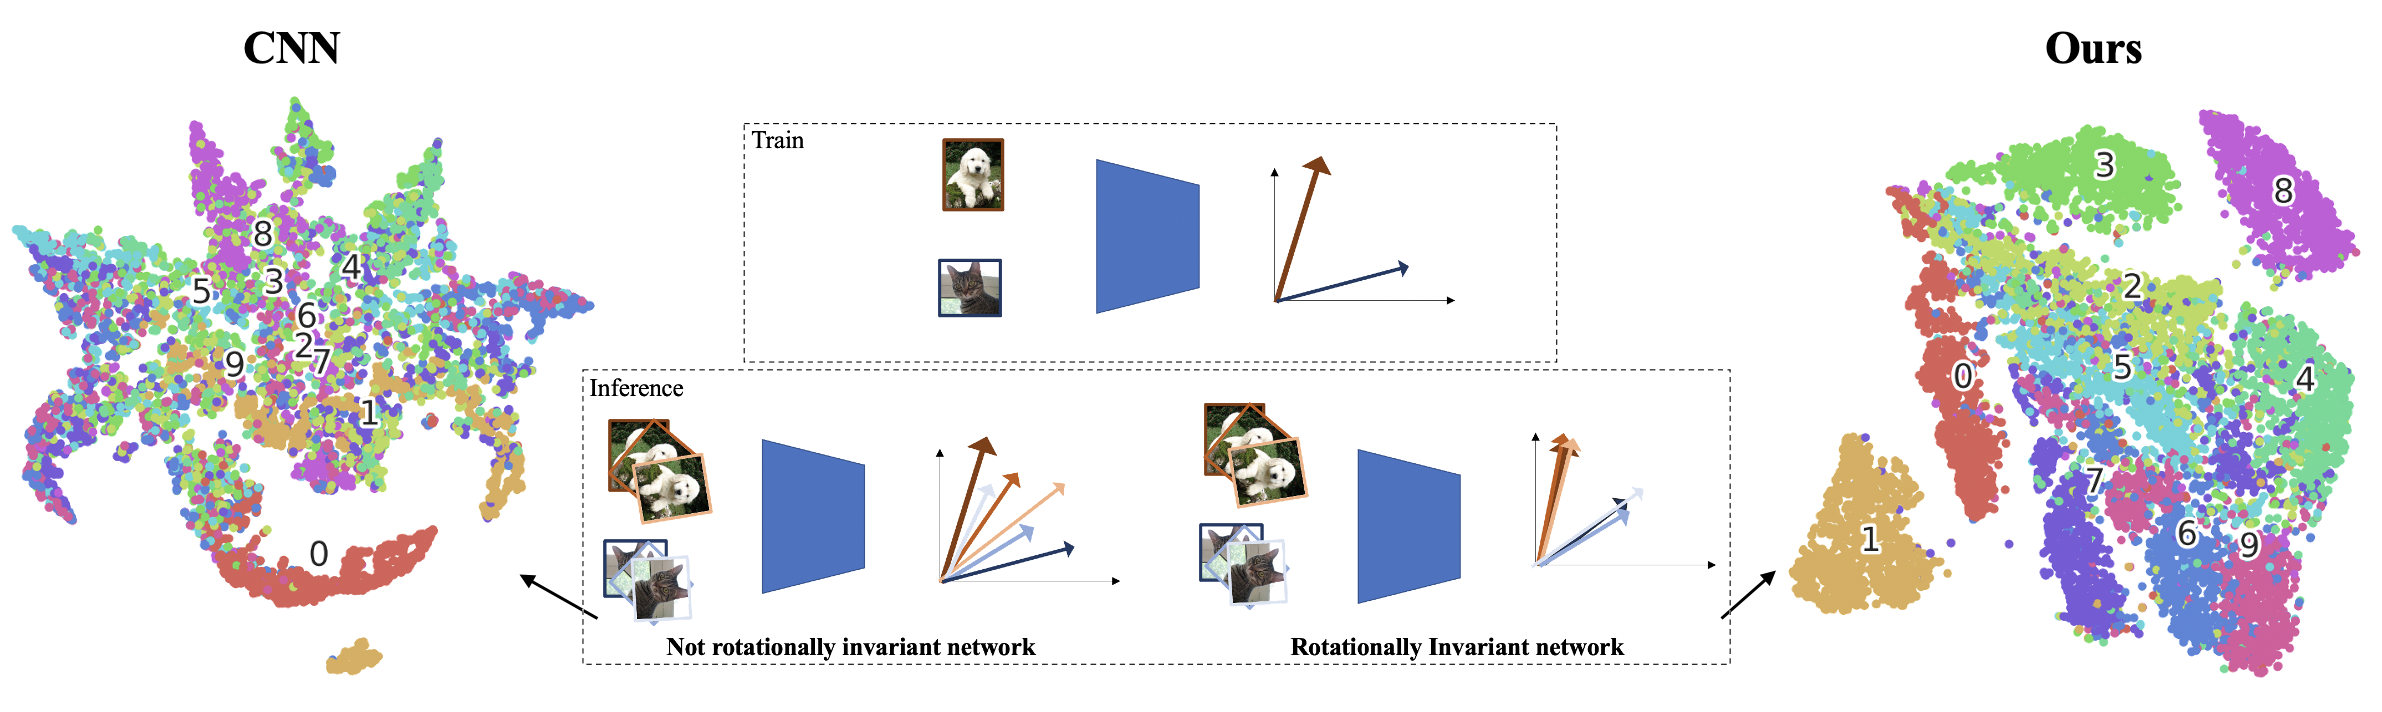
  • Equivariance-bridged SO(2)-Invariant Representation Learning using Graph Convolutional Network

    Sungwon Hwang, Hyungtae Lim, Hyun Myung

    The British Machine Vision Conference (BMVC), 2021

    Paper | Code

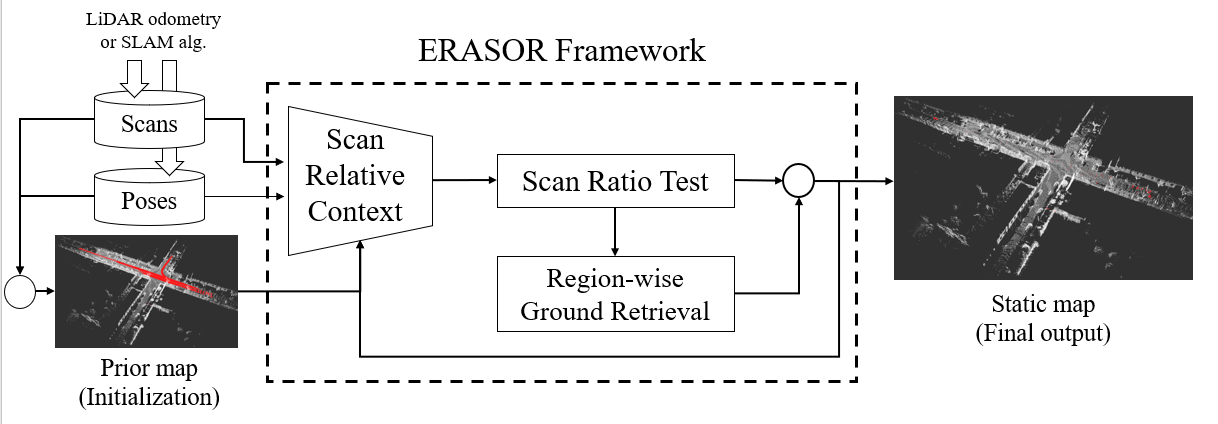
  • ERASOR: Egocentric Ratio of Psuedo Occupancy-based Dynamic Object Removal for Static 3D Point Cloud Map Building

    Hyungtae Lim, Sungwon Hwang, Hyun Myung

    IEEE Robotics and Automation Letters (RA-Letters)

    Paper | Code

  • Normal Distributions Transform is Enough: Real-time 3D Scan Matching for Pose Correction of Mobile Robot

    under Large Odometry Uncertainties

    Hyungtae Lim*, Sungwon Hwang*, Sungjae Shin, Hyun Myung (*: equal contribution)

    International Conference on Control, Automation and Systems (ICCAS), 2020

    Paper | Video

  • Text2Control3D: Controllable 3D Avatar Generation in Neural Radiance Fields using Geometry-Guided Text-to-Image

    Diffusion Model

    Sungwon Hwang, Junha Hyung, Jaegul Choo

    arXiv preprint

    Paper | Project Page | Code